

Agenticros — Development skill for Claude Code
ROS plugin for OpenClaw, Claude (Code,Desktop,Dispatch), Codex, Google Gemini, Hermes, MCP, etc.
How to install Agenticros
This entry records only its repository, not the path inside it, so there is no
exact command to give. Open agenticros/agenticros and copy the folder into
~/.claude/skills/, or the file into ~/.claude/agents/.
What Agenticros does
ROS plugin for OpenClaw, Claude (Code,Desktop,Dispatch), Codex, Google Gemini, Hermes, MCP, etc.
Alternatives in Development
- Petdex — A public gallery of animated pets for Codex, Claude Code, DeepSeek Harness, Hermes, OpenCode, Gemini CLI, and 4k ★
- Agentic Stack — One brain, many harnesses 2.2k ★
- Phistory — Phistory automatically archives versioned system prompt snapshots from agent CLIs like Claude Code, Codex, Ope 560 ★
README
AgenticROS
    _                     _   _       ____   ___  ____
   / \   __ _  ___ _ __ | |_(_) ___ |  _ \ / _ \/ ___|
  / _ \ / _` |/ _ \ '_ \| __| |/ __|| |_) | | | \___ \
 / ___ \ (_| |  __/ | | | |_| | (__ |  _ <| |_| |___) |
/_/   \_\__, |\___|_| |_|\__|_|\___||_| \_\___/|____/
        |___/
  AgenticROS - agentic AI for ROS-powered robots
**Physical AI Agents for ROS Robots**

[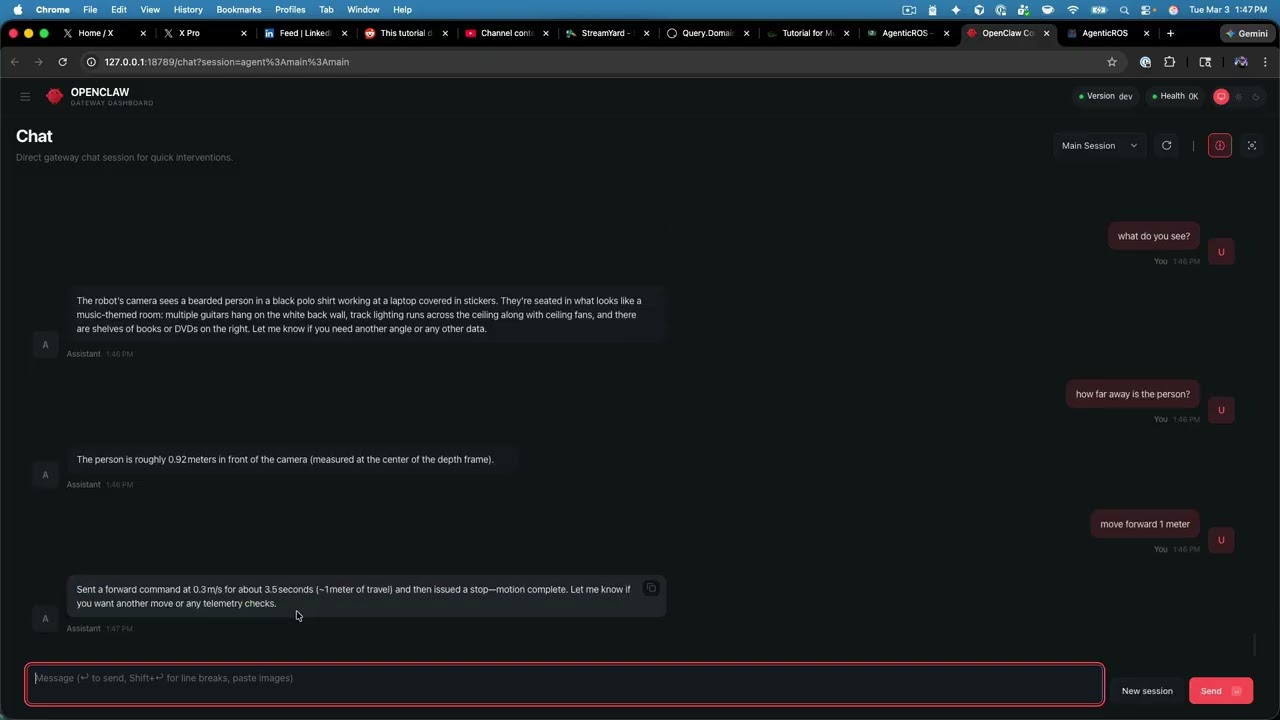](https://www.youtube.com/watch?v=_fbWhYcPj0M)
▶ [Watch the AgenticROS intro on YouTube](https://www.youtube.com/watch?v=_fbWhYcPj0M)
AgenticROS turns ROS 2 robots into agent-native machines. Speak, type, or message — and your robot perceives, reasons, and acts. It is an open, AI-agent-agnostic interface layer that bridges the world of frontier reasoning models with the world of cameras, depth sensors, motors, and `cmd_vel`, so robots stop being remote-controlled tools and start collaborating like teammates.
With AgenticROS, your robot can describe what it sees, follow intent ("go check the front door"), run skills you author, and respond to natural language across the agent platforms you already use. **One ROS 2 workspace, one config, many agents.**
**Building a robot from parts?** Start with the **[hardware getting started guide](docs/hardware.md)** — reference BOM (Jetson or Pi / RADXA / LattePanda / x86+Arduino), L298N GPIO wiring for `/cmd_vel` and `/odom`, RealSense, then OpenClaw and other agents.
Supported AI Agent platforms
- OpenClaw — Native gateway plugin with ROS 2 tools, commands, a config UI, a teleop web app, and a skill loader. The flagship integration.
- NVIDIA NemoClaw — Run AgenticROS inside NemoClaw's OpenShell sandbox with policy-enforced egress and managed NVIDIA inference; ROS 2, RealSense, and rosbridge stay on the hos
Related Skills

Cc Switch Remote
A cross-platform desktop All-in-One assistant for Claude Code, Codex, OpenCode, OpenClaw, Gemini CLI & Hermes

Cc Switch
A cross-platform desktop All-in-One assistant for Claude Code, Codex, OpenCode, OpenClaw, Gemini CLI & Hermes


Agent Mux
unified TypeScript SDK and CLI (amux) for driving heterogeneous coding-agent harnesses — Claude Code, Codex, G


Agentburn Gui
Profileur local et natif de la consommation des agents de code : Claude Code, Codex, Gemini, opencode, OpenCla

QuotaDock
Windows desktop widget that monitors Claude, OpenAI Codex, and Google Antigravity (Gemini) usage limits, quota
Hodios
Hodios — open prompts by Hermes IDE. Expert prompts, personas and workflows for work, learning, creativity and

Related Agents

Ensemble Curator
High-volume triage agent for external-AI-agent PRs (Codex, Jules, Hermes, Droid, Aider, etc.). Analyzes, conso


Gemini Researcher
Use this agent to orchestrate comprehensive multi-perspective research using Google's Gemini model. Breaks dow

Adk Reviewer
Reviews Google ADK 1.29.0 agent code. Checks ADK-specific patterns, tool contracts, session management, SSE st
